Open CoPAEI · Humanoid platform
Open SourceMulti-FormHumanoid.
Engineered for motion.
Designed for the future.
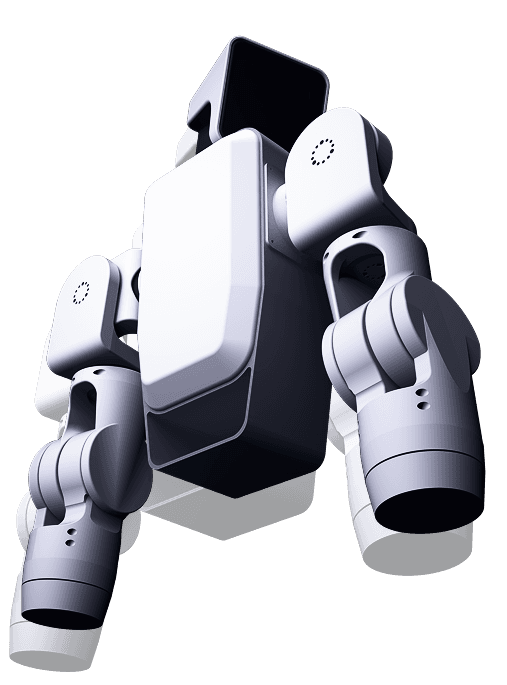
01 – Torso
Single Torso unit for dual form factor
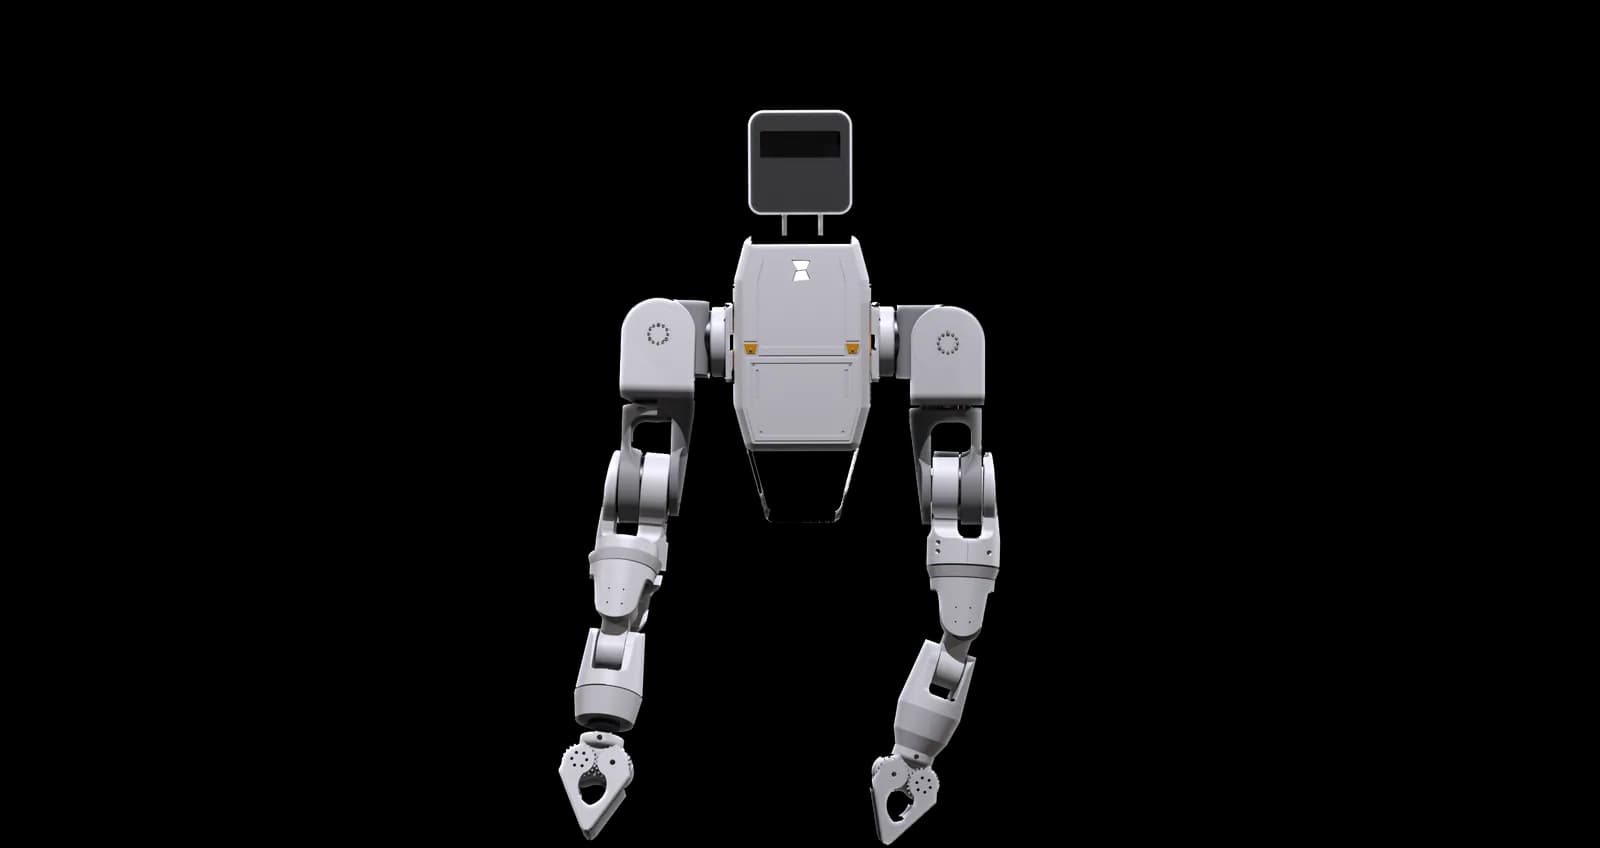
02 – Bimanual
Two arms with two types of easily interchangeable grippers.
Mount it on any table and immediately begin teleoperation and data collection.
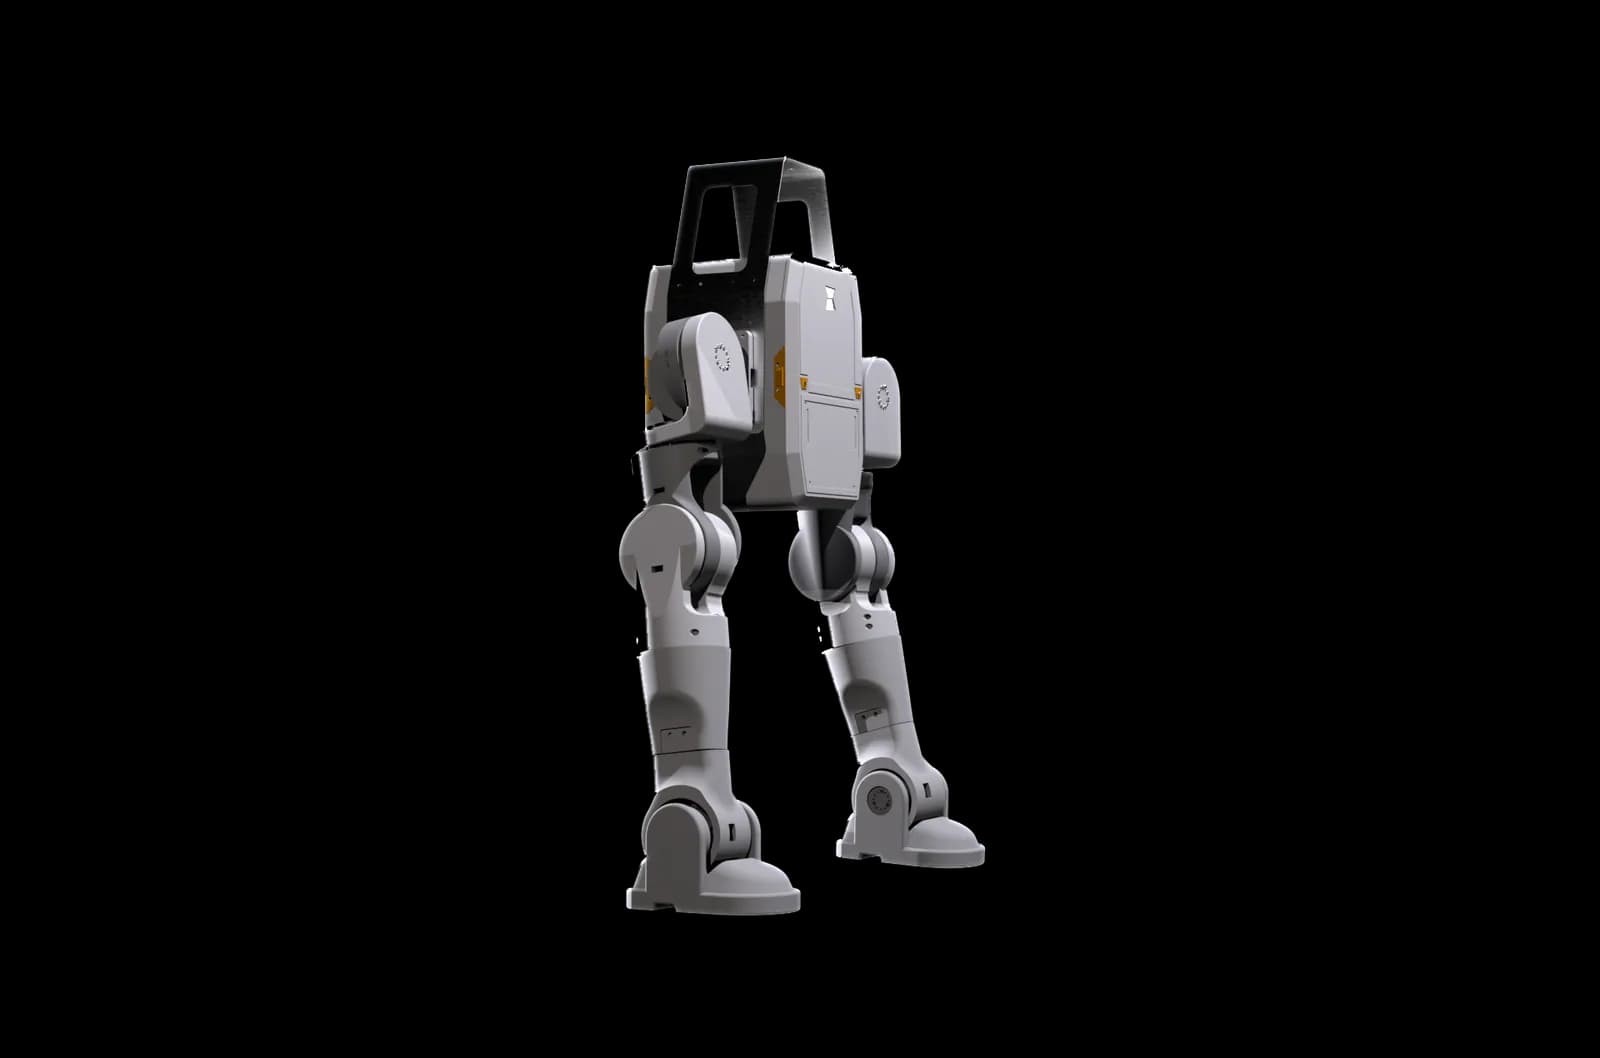
03 – Bipedal
Easily swappable leg modules.
Imagine the bipedal robot equipped with either feet or wheels.
We have built world’s first multi-form Humanoid Robot, democratising the access to robotics policy training.
02 · Anatomy · 01
Core module
Two 22 000 mAh packs, the compute and the 2-axis head live in one sealed torso. Both configurations bolt to the same core.
- 10 kg torso · 5.2 kg of battery
- Raspberry Pi 5 · 8 GB
- 2-axis head · 2 camera modules
02
Bimanual
Two arms on that core. Shoulder, elbow and wrist stack into a limb precise enough for tools built for human hands.
- 9 DOF per arm · 9 motors
- 15 kg payload
- 800 mm minimum reach
03
Bipedal
The same core on two legs. Five motors in each leg carry the machine across ground that was never prepared for it.
- 5 DOF per leg · 5 motors
- 10.5 kg per leg
- 31 kg in bipedal mode
03 · Capabilities
One body.Four disciplines.
- 0110 DOF · 5 motors per leg
Mobility
Advanced locomotion and dynamic balance across uneven, unstructured terrain.
- 022 × Camera Modules
Perception
Multi-modal sensing and environmental awareness, fused in real time.
- 039 DOF per arm · 15 kg payload
Manipulation
Precise, human-like interaction with objects, tools and interfaces.
- 04Raspberry Pi 5 · 8 GB on-board
Intelligence
AI-driven perception, planning and decision making, on-board and offline.
04 · Numbers
- 20DOFBimanual mode
- 10DOFBipedal mode
- 15kgPayload per arm
- 800mmMinimum arm reach
05 · Data
Numbers that
hold up.
Bimanual mode
- Total DOF
- 20
- Total weight
- 29 kg
- DOF per arm
- 9 · 9 motors
- Arm weight
- 9.5 kg each
- Payload per arm
- 15 kg
- Minimum arm reach
- 800 mm
Bipedal mode
- Total DOF
- 10
- Total weight
- 31 kg
- DOF per leg
- 5 · 5 motors
- Leg weight
- 10.5 kg each
Torso
- Torso weight
- 10 kg
- Head DOF
- 2
- Battery
- 2 × 6S LiPo · 22 000 mAh
- Battery count
- 2
Compute & sensing
- Main computing unit
- Raspberry Pi 5 · 8 GB
- Motor controllers
- Robstride
- Head cameras
- 2 × Camera Modules
- Camera
- 1440 × 1080 · 1.5 MP · 60 fps
06 · Unsupervized Open CoPAEI vs LimX TRON 2
More reach.
More joints.
DOF per arm
+2 jointsMaximum arm reach
+37% reach- DOF per arm
- Open CoPAEI✓9+2
- TRON 27
- Maximum arm reach
- Open CoPAEI✓1000 mm+37%
- TRON 2730 mm
- Openness
- Open CoPAEI✓Open source
- TRON 2Open SDK
- Head cameras
- Open CoPAEIStereo · 2 × 1.5 MP · 60 fps
- TRON 2Front camera
- Form factors
- Open CoPAEIBimanual · Bipedal
- TRON 2Dual arm · Wheeled · Bipedal
- Arm payload
- Open CoPAEI✓15 kg per arm
- TRON 210 kg dual-arm
| Specification | Open CoPAEI | LimX TRON 2 |
|---|---|---|
| DOF per arm | ✓9+2 | 7 |
| Maximum arm reach | ✓1000 mm+37% | 730 mm |
| Openness | ✓Open source | Open SDK |
| Head cameras | Stereo · 2 × 1.5 MP · 60 fps | Front camera |
| Form factors | Bimanual · Bipedal | Dual arm · Wheeled · Bipedal |
| Arm payload | ✓15 kg per arm | 10 kg dual-arm |
Early access · 2027 program
Own your Robot today.
We are onboarding a limited number of research and industrial partners for the first Open CoPAEI production run.